Our research
Sense. Understand. Act.
Useful autonomy depends on more than an algorithm. We study the connection between perception, decision-making, and the systems that run them.
01 / Research direction
Perception & mapping
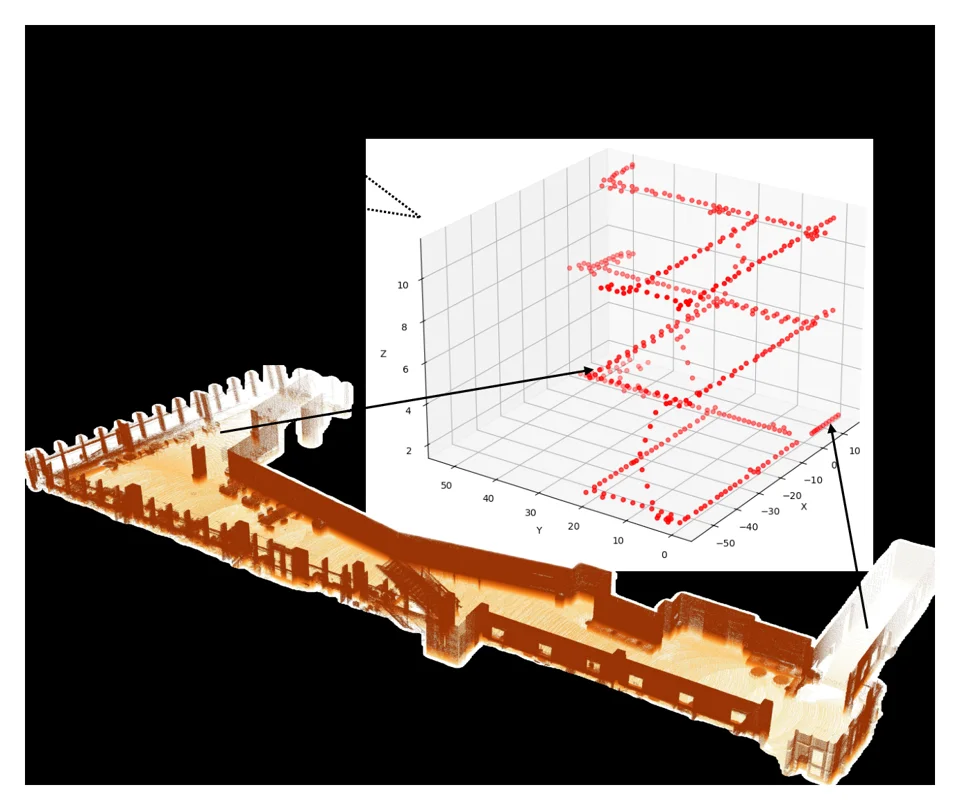
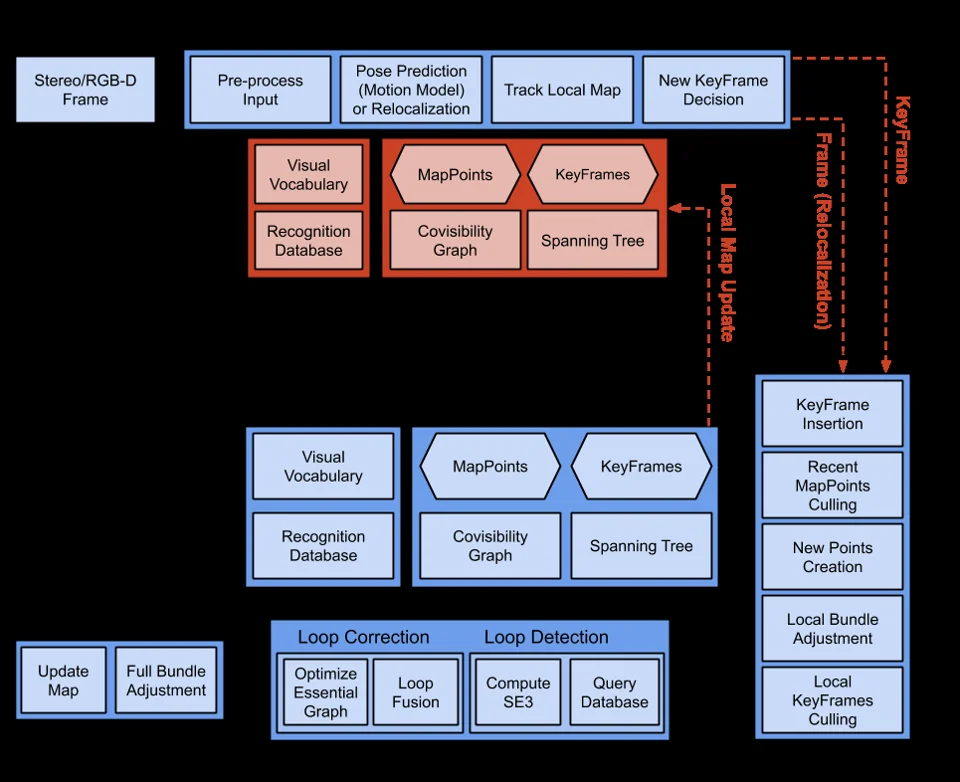
We study how robots extract reliable information from visual, geometric, and wireless signals. Our work spans visual odometry, SLAM, multi-robot mapping, and evaluating the quality of 3D reconstructions.
02 / Research direction
Robot autonomy
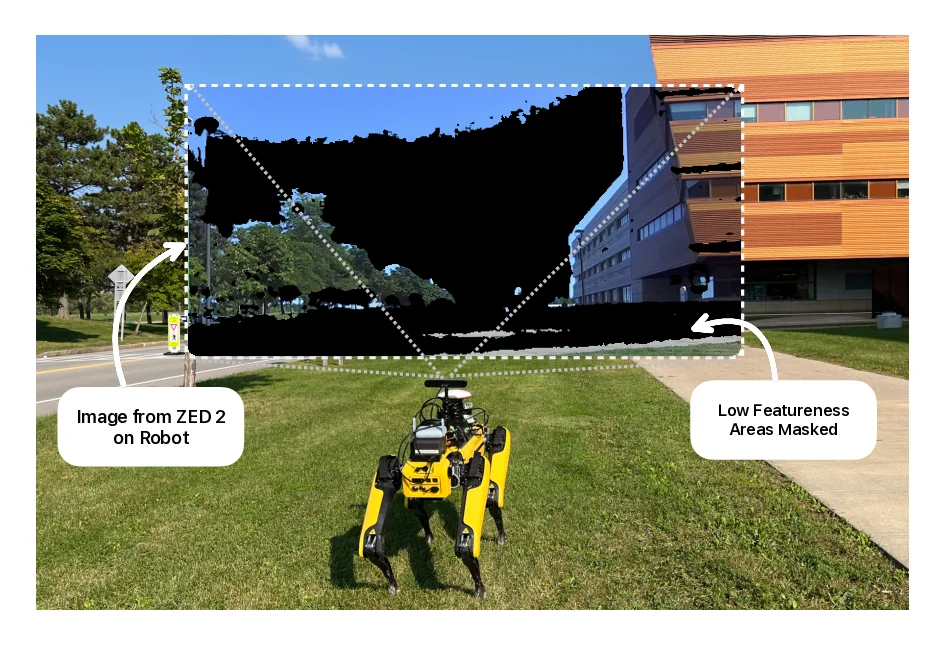
We explore the representations and planning methods that connect sensing to action. Terrain-aware navigation and energy-efficient coverage planning help robots operate across different environments and mission scales.
03 / Research direction
Sensing & systems
We design sensing and computing systems that respect real deployment constraints. Edge-assisted computation, energy accounting, and physics-informed sensing connect efficient algorithms with practical applications, including plastics sorting.
A place to ask the next question
Let’s build what comes next.
Interested in robotics, perception, or embedded systems?
Get to know our work and connect with the lab.