Perception / 2026
Empir3D
Evaluate 3D reconstructions through resolution, accuracy, coverage, and artifacts.
About the project
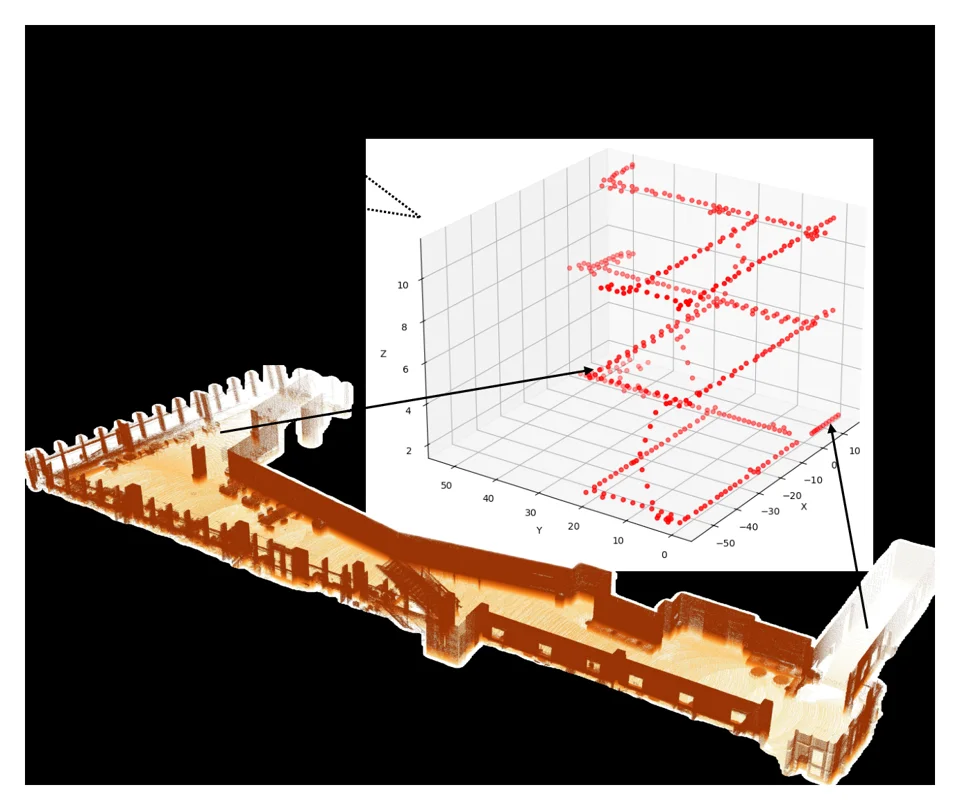
Empir3D evaluates point clouds along four complementary dimensions. Its metrics expose different kinds of degradation that can be hidden by a single distance score, helping researchers assess SLAM and point-cloud completion systems.
What it enables
The framework makes reconstruction quality easier to diagnose by separating missing coverage, registration error, resolution, and artifacts.