Research in practice
Projects.
Ideas, experiments, and systems—from reliable visual perception to autonomous robots and sustainable sensing.
Applications
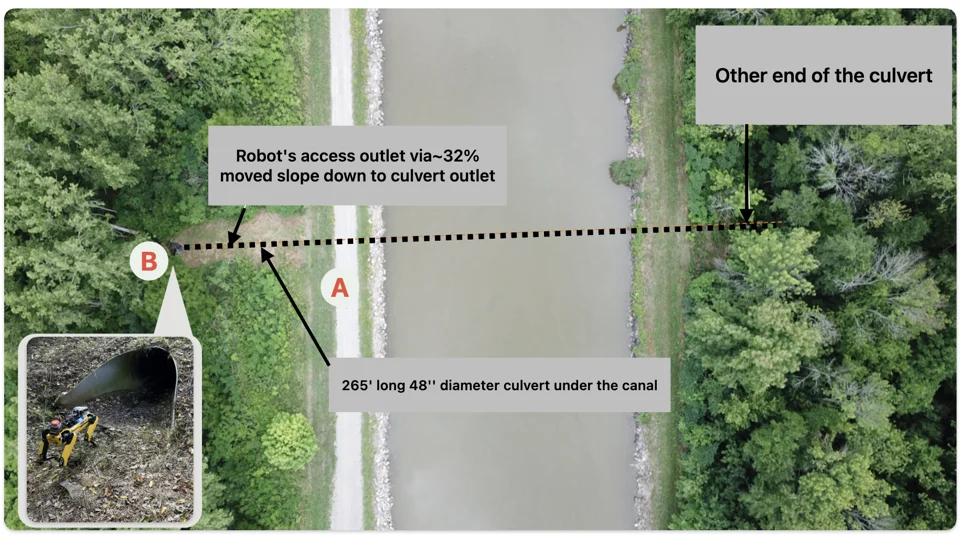
INSPECTOR
Autonomous culvert inspection with legged robots in challenging field conditions.
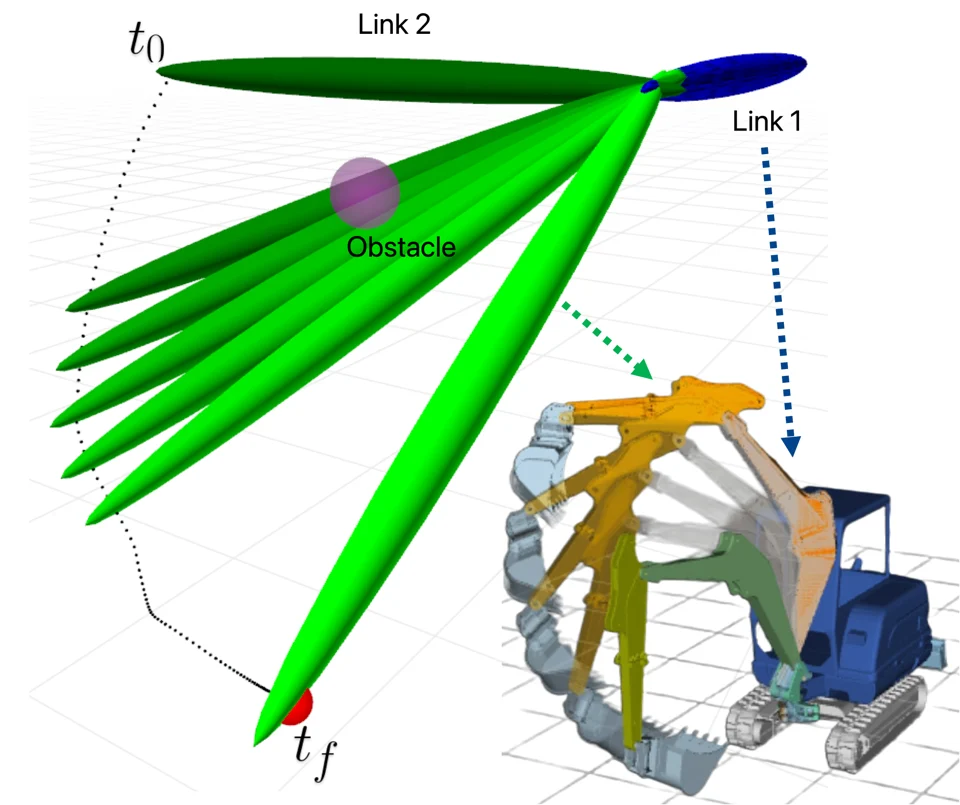
EARTH
Perception, planning, and hydraulic control for autonomous excavation.
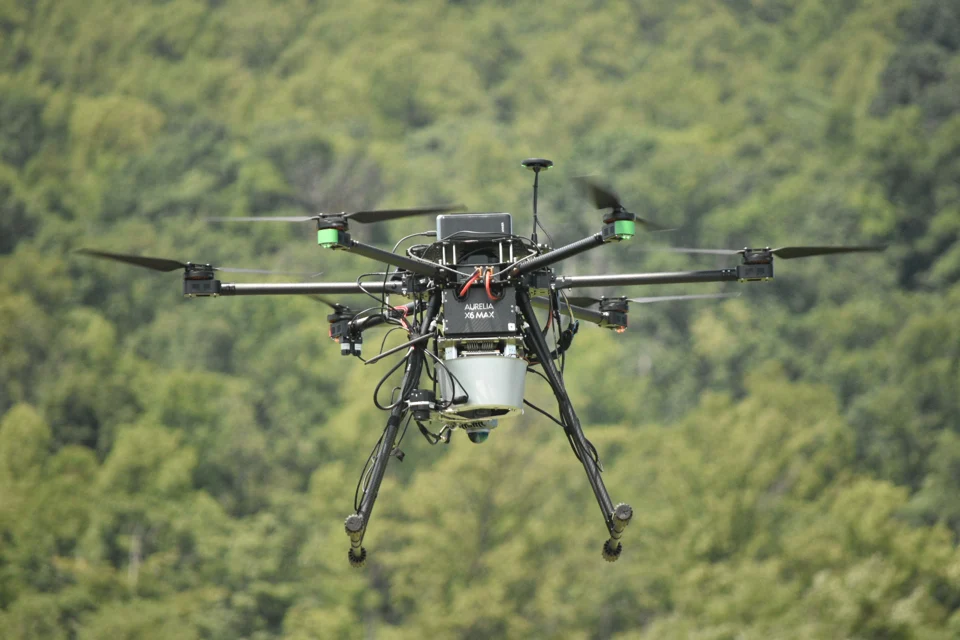
VISTA
Allocate limited flight time to informative measurements of vegetation condition.
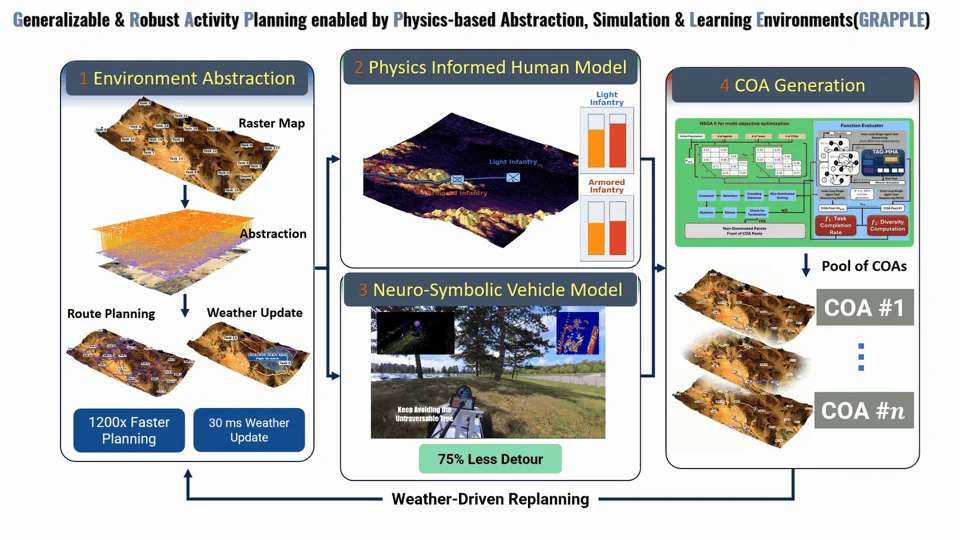
ONR-GRAPPLE
Connect terrain representations and mobility models to robust mission planning.
Representation
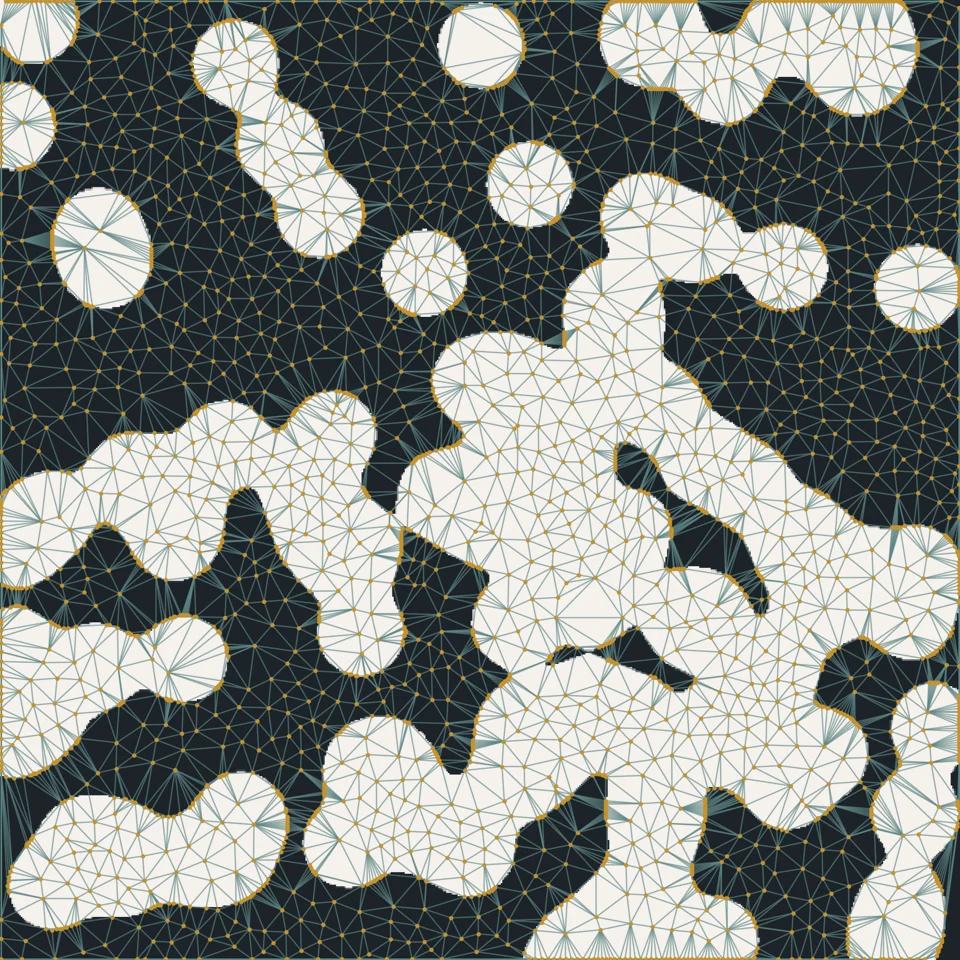
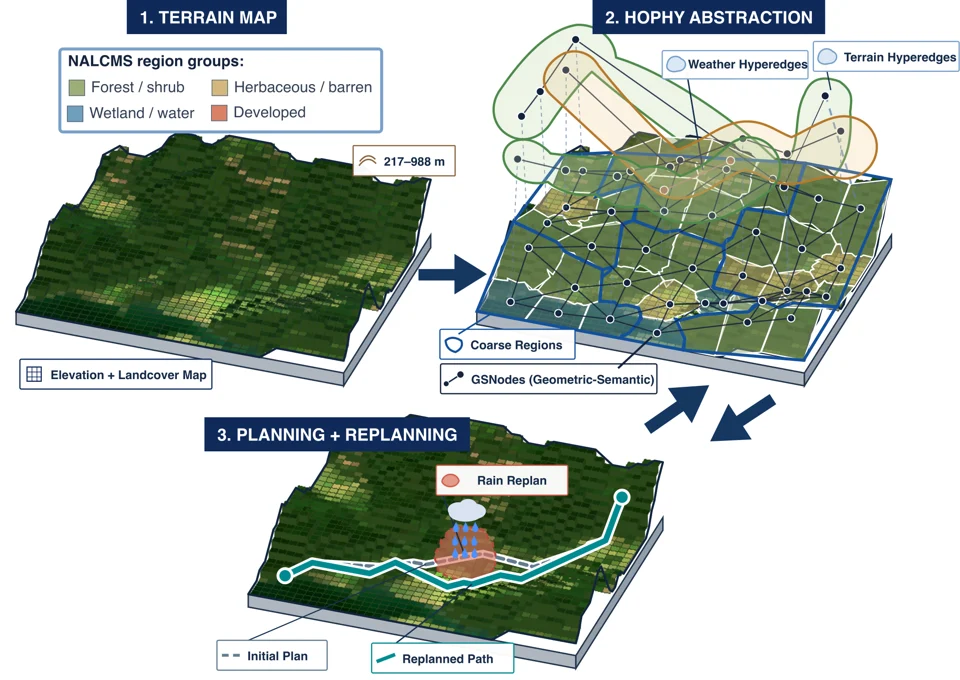
Perception
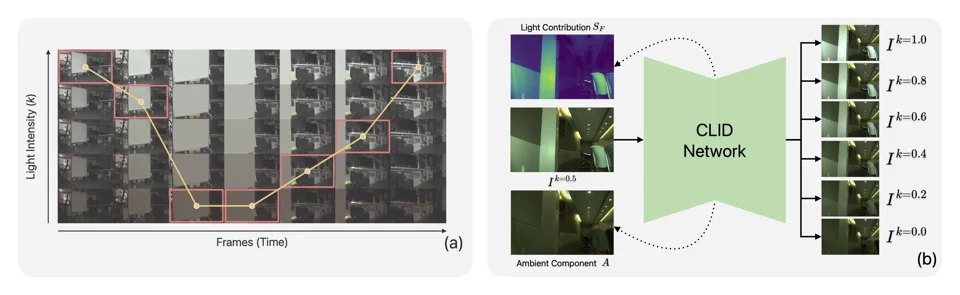
LGTN
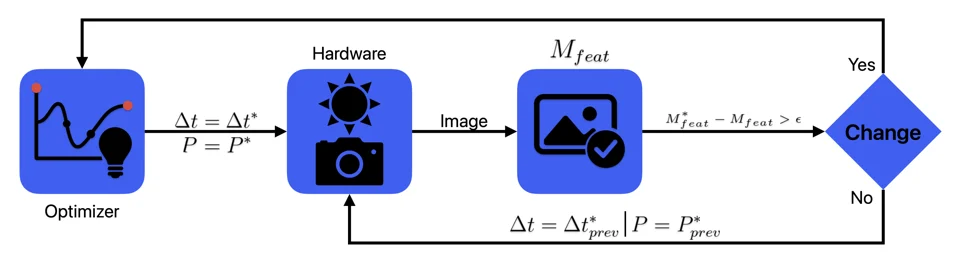
Learn how to control onboard lighting for more reliable robot perception.
NH
Adapt illumination and camera exposure for visual estimation in dark environments.
PIXER
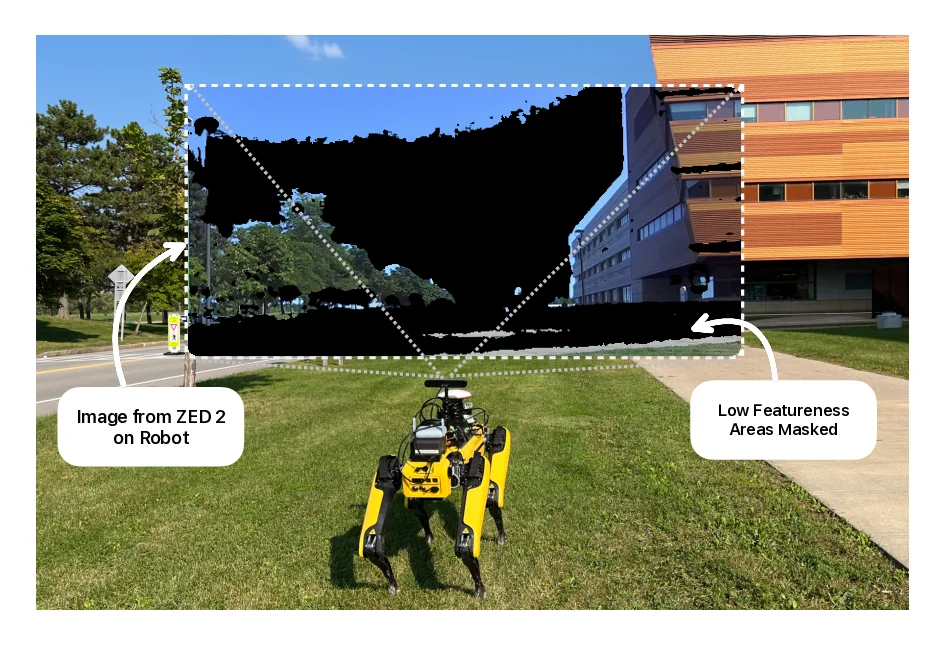
Learn which pixels to trust for more reliable, efficient visual navigation.
E3D
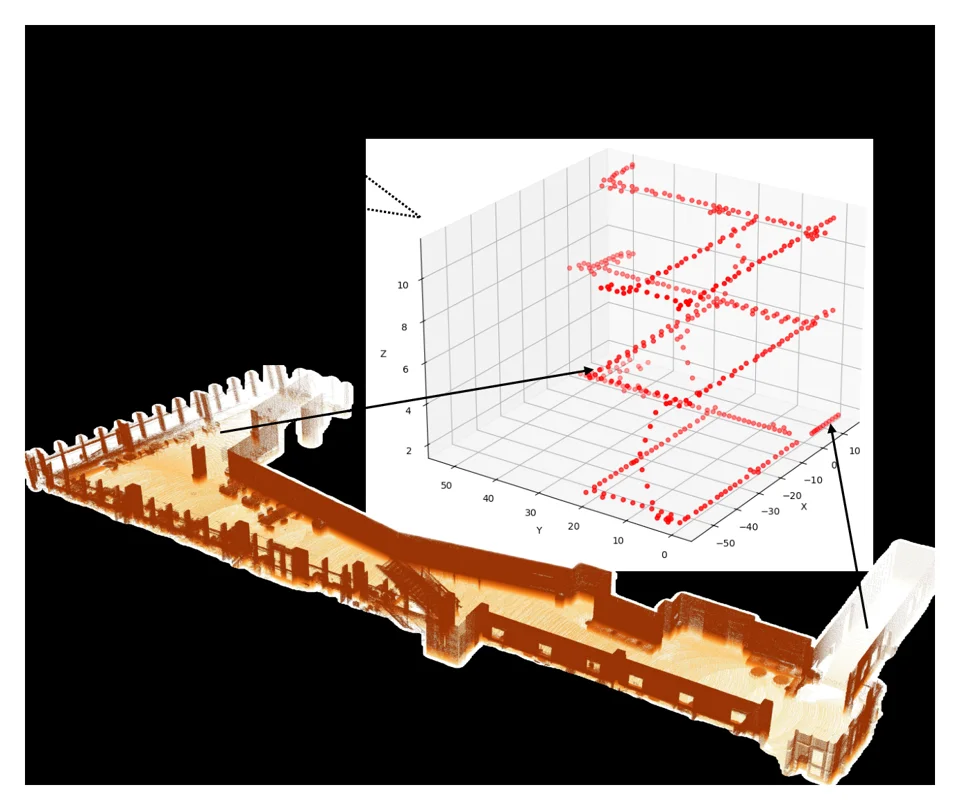
Evaluate 3D reconstructions through resolution, accuracy, coverage, and artifacts.
Planning
SENTINEL
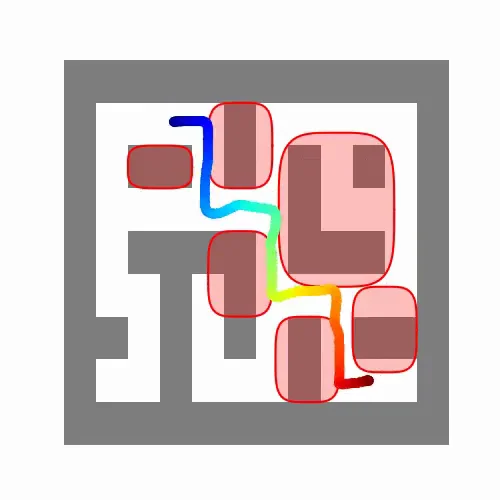
Constraint-aware trajectory sampling for safe, efficient robot motion.
LeggedLocomotion
Connect robot–terrain interaction with locomotion adaptation and risk-aware navigation.
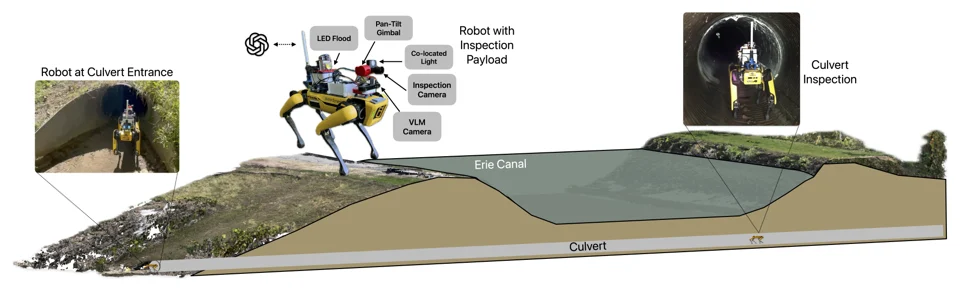
VISION
Language-guided observation and navigation for autonomous culvert inspection.