Autonomy / 2026
CLEAR
Turn large terrain maps into compact, terrain-aware graphs for off-road planning.
About the project
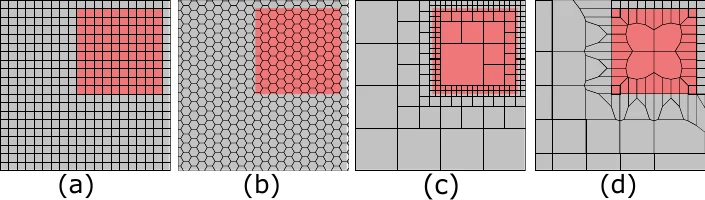
CLEAR constructs a reusable terrain abstraction from landcover and elevation. Boundary-seeded decomposition, recursive plane fitting, and graph encoding preserve semantic and geometric structure while making large maps easier to plan over.
What it enables
The abstraction supports long-horizon planning across kilometer-scale terrain, with executability evaluated in physics-based simulation.