Perception / 2026
PIXER
Learn which pixels to trust for more reliable, efficient visual navigation.
About the project
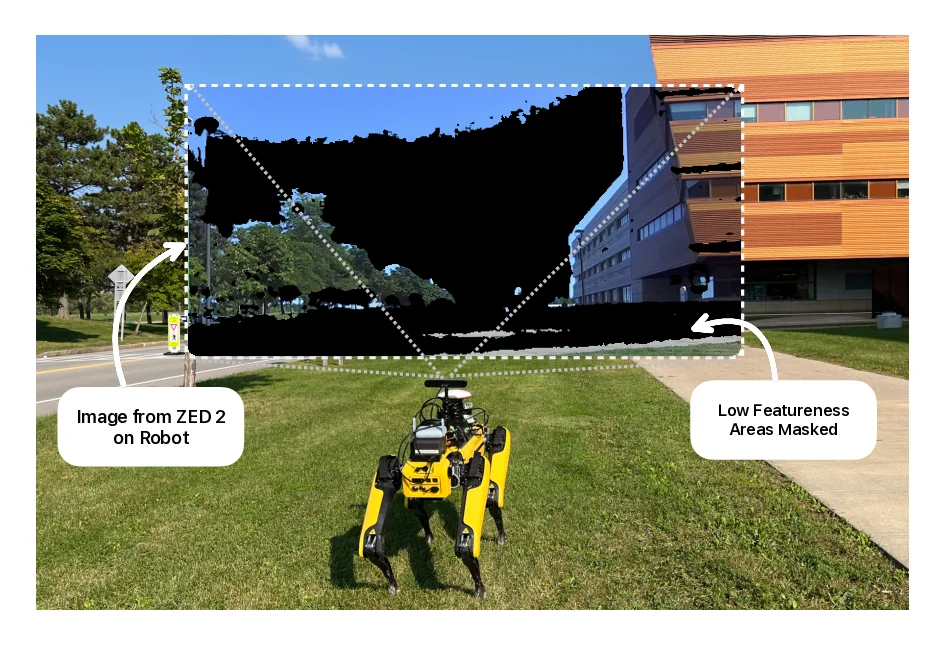
PIXER predicts a dense reliability map from a single image and filters low-utility features before matching. A lightweight self-supervised network makes this usable as a preprocessing step for feature-based visual navigation.
What it enables
Across eight feature detectors, the project reports improved trajectory accuracy while using fewer features.