Systems / 2020
Edge-SLAM
Split visual SLAM between mobile devices and edge computing to sustain long-running operation.
About the project
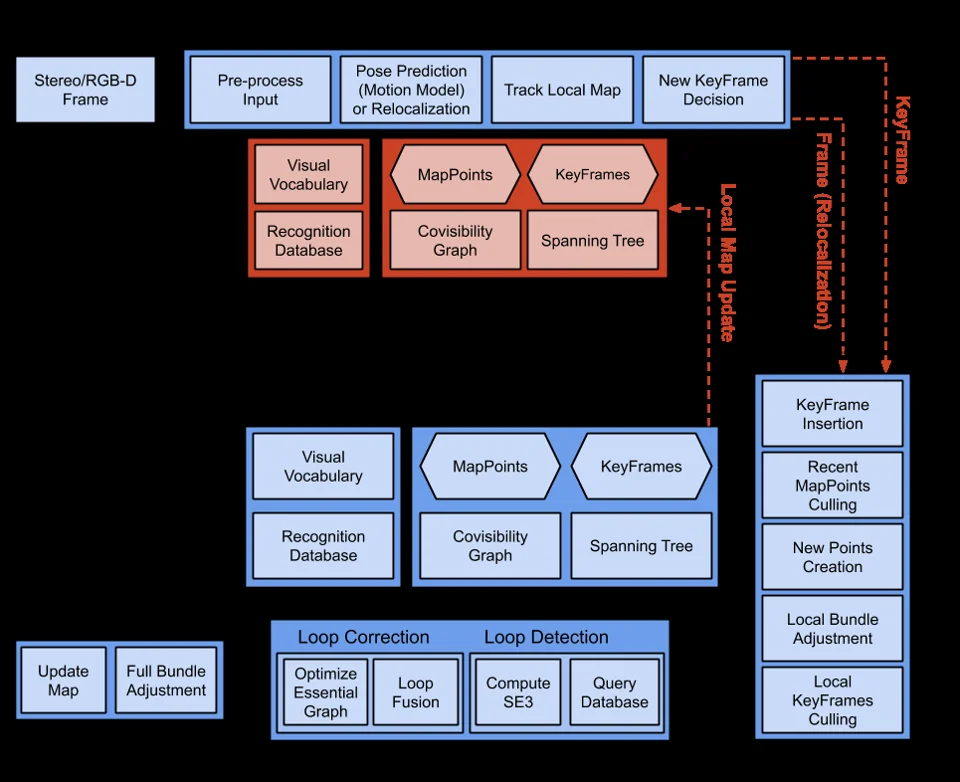
Edge-SLAM is an edge-assisted visual simultaneous localization and mapping. Edge-SLAM adapts Visual-SLAM into edge computing architecture to enable long operation of Visual-SLAM on mobile devices. This is achieved by offloading the computation-intensive modules to the edge. Thus, Edge-SLAM reduces resource usage on the mobile device and keeps it constant. Edge-SLAM is implemented on top of ORB-SLAM2 and is publicly available on GitHub.
Related publications
-
Edge-SLAM: Edge-Assisted Visual Simultaneous Localization and Mapping
Ali J. Ben Ali , Zakieh Hashemifar , Karthik Dantu
Proceedings of the 18th International Conference on Mobile Systems, Applications, and Services, 2020 , pp. 325–337
Project Page | PDFBibTeX
@inproceedings{edgeslam,
  author = {Ben Ali, Ali J. and Hashemifar, Zakieh Sadat and Dantu, Karthik},
  title = {Edge-SLAM: Edge-Assisted Visual Simultaneous Localization and Mapping},
  year = {2020},
  isbn = {9781450379540},
  publisher = {Association for Computing Machinery},
  address = {New York, NY, USA},
  url = {https://doi.org/10.1145/3386901.3389033},
  doi = {10.1145/3386901.3389033},
  booktitle = {Proceedings of the 18th International Conference on Mobile Systems, Applications, and Services},
  pages = {325–337},
  numpages = {13},
  keywords = {mobile systems, mapping, visual simultaneous localization and mapping, split architecture, localization, edge computing},
  location = {Toronto, Ontario, Canada},
  series = {MobiSys '20}
}